Mingtao Wang - 王铭涛 - Homepage
Down-to-earth, quietly brilliant; still
waters run deep.
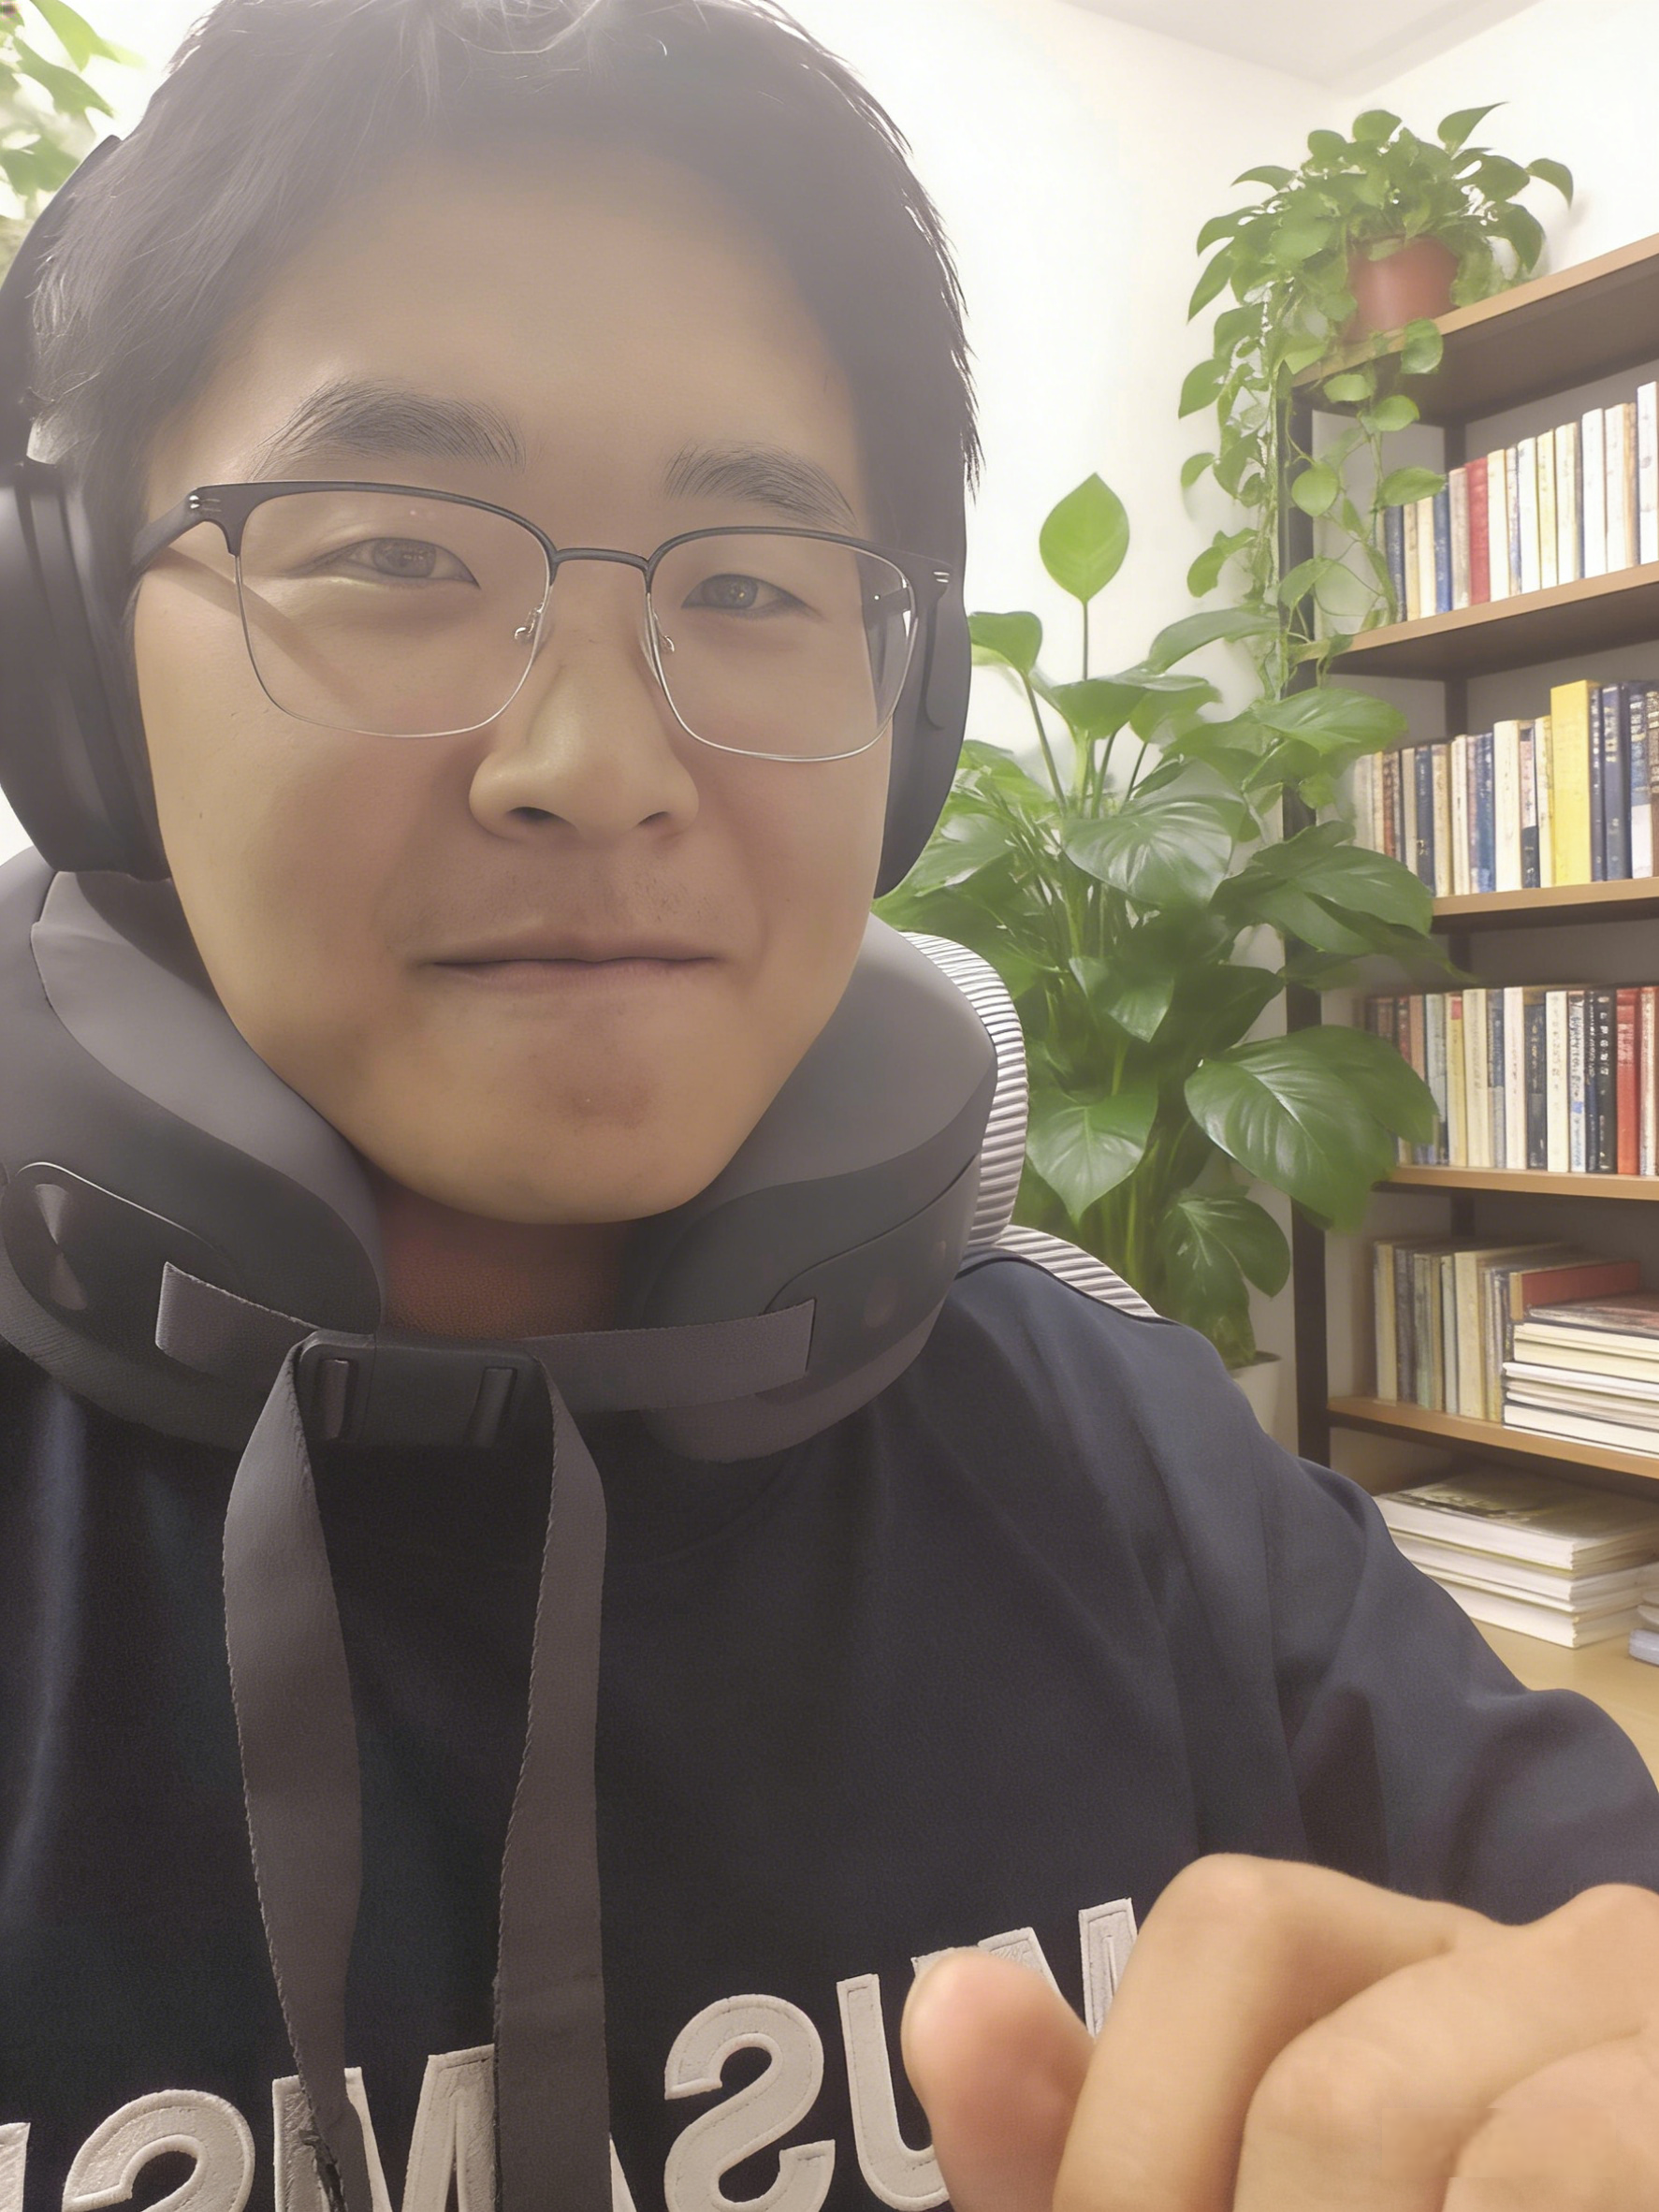
 I am currently a master's student affiliated with the School of Artificial
Intelligence, the School of Geosciences and Info-Physics, and Xiangjiang Laboratory at Central South University,
under the joint supervision of Prof. Chao Tao and Prof. Haifeng Li. My research focuses on embodied intelligence for unmanned aerial vehicles (UAVs),
including AI-based UAV localization and navigation, UAV vision-language-action models, and UAV vision-language navigation. From the second semester of
my senior year through the first semester of my master's program, I worked as an AI full-stack
application development software engineer at a startup incubated by Central South University. Prior
to that, I received my bachelor's degree from Northeastern University in 2025, under the supervision
of Prof. Defu Che.
 QQ:673827321 
 gmail:wmingtao624@gmail.com  email:255011016@csu.edu.cn |
|
|
 Biography
 Feel free to contact me by email if you are interested in discussing or collaborating with
me.
 Education & Visiting
|
Central South University, Changsha, China, 985, 211 M.S. in Remote Sensing Science and Technology Advisors: Prof. Chao Tao and Prof. Haifeng Li Sep. 2025 - Jun. 2028 |
|
Northeastern University, Shenyang, China, 985, 211 B.Eng. in Surveying and Mapping Engineering Advisor: Prof. Defu Che Sep. 2021 - Jun. 2025 |
 Selected Publications
|
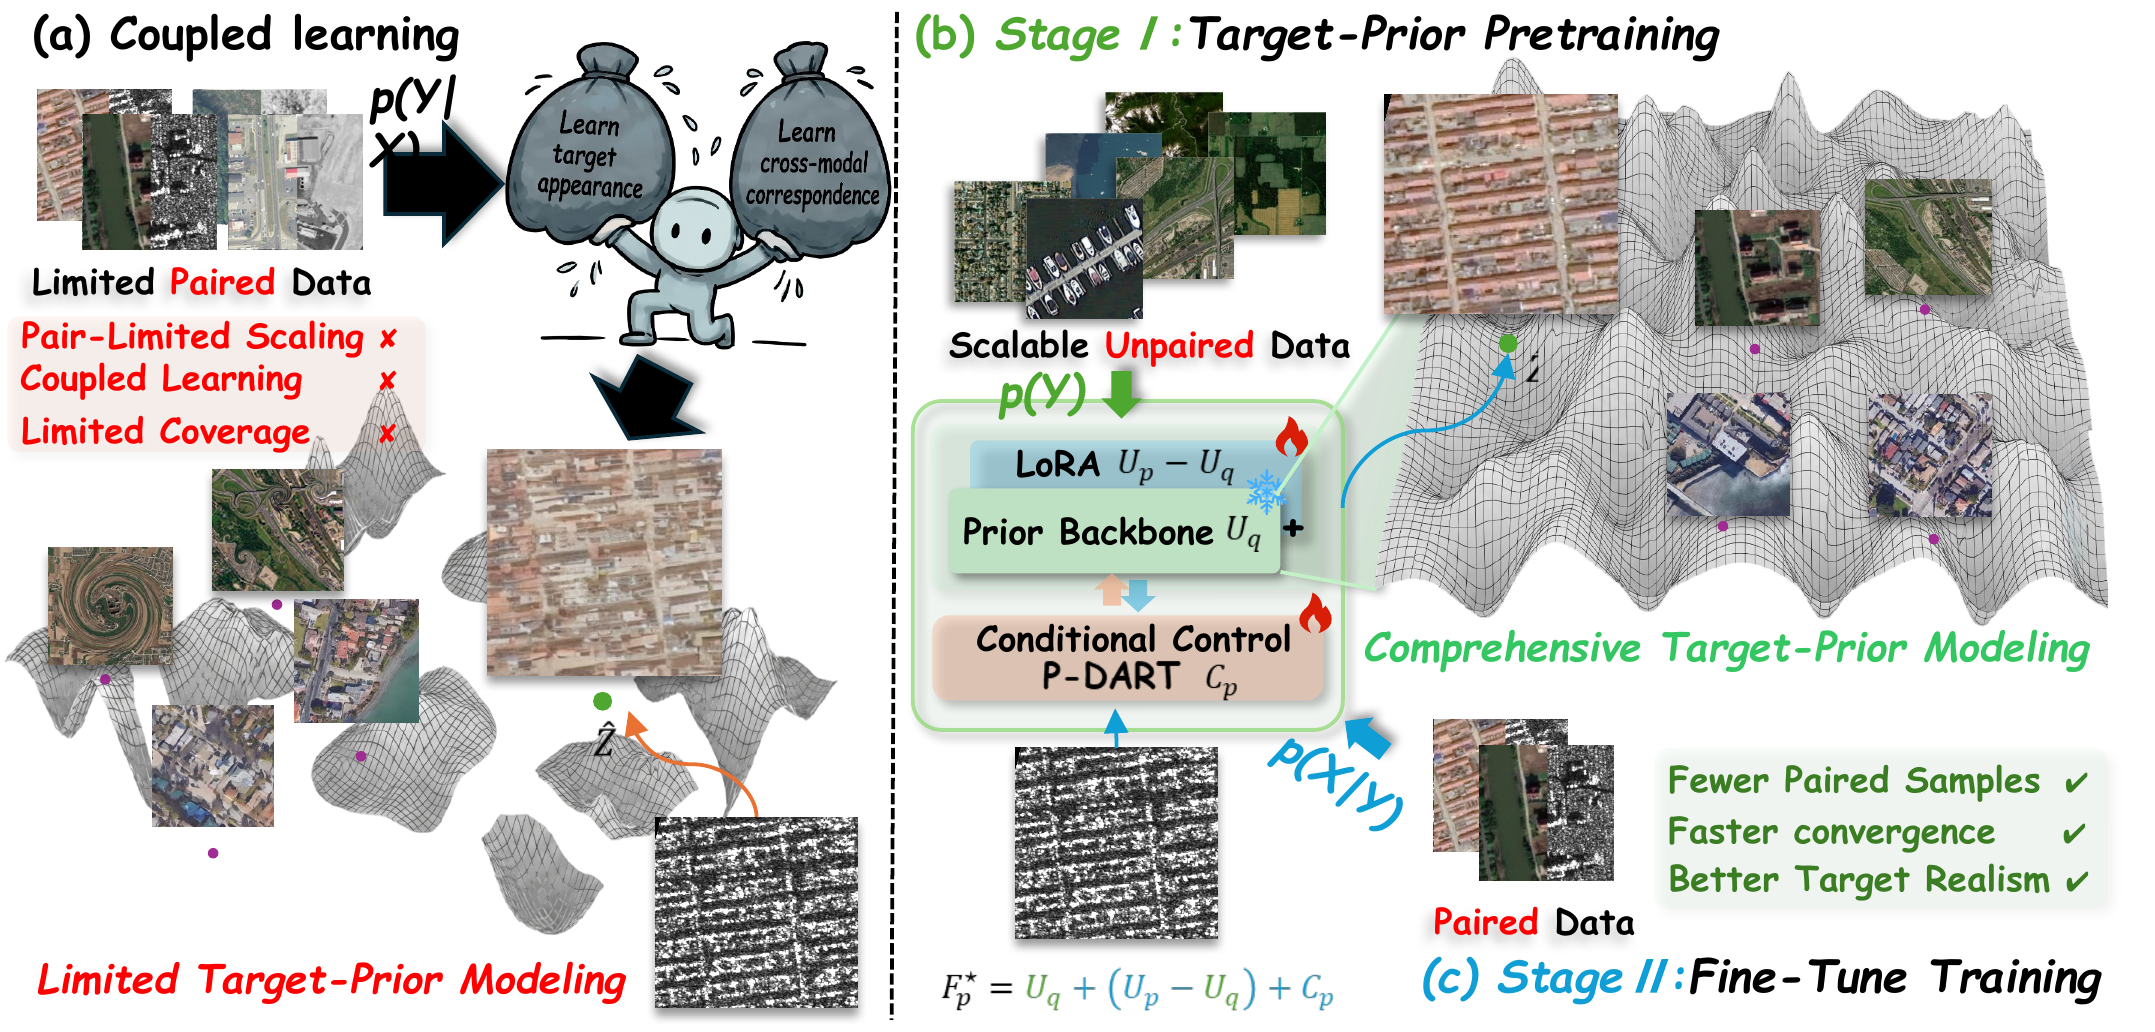
Keyan Hu*, Mingtao Wang*, Ji Qi, Ziyu Zhou, Tiandong Shi, Haifeng Li, and Chao Tao Released: Aug. 1, 2026 (Preprint) |
 Project Experience
VLA Model Training and Real-World Deployment for High- and Low-Altitude UAV Target Interaction Tasks
- Reproduced research implementations, configured multi-GPU training, and deployed trained models on a physical UAV. Built a distributed training environment with 8 NVIDIA RTX PRO 6000 GPUs and performed both full-parameter and LoRA fine-tuning of π0 and π0.5 on HUGE-Bench, reproducing related ECCV 2026 work and validating inference and action execution in simulation.
- Applied LoRA fine-tuning to OpenVLA, π0, and π0.5 on the UAV-Flow dataset to reproduce related NeurIPS 2025 work.
- Designed a ROS-based cloud-edge communication protocol and addressed remote-inference latency through a collaborative framework combining cloud-based VLA semantic decision-making with onboard obstacle avoidance, trajectory planning, and control. Validated the framework in NVIDIA Isaac Sim, conducted real-world deployment tests, and completed closed-loop data evaluation.
Design of a Physical UAV Agent System for Embodied Tasks
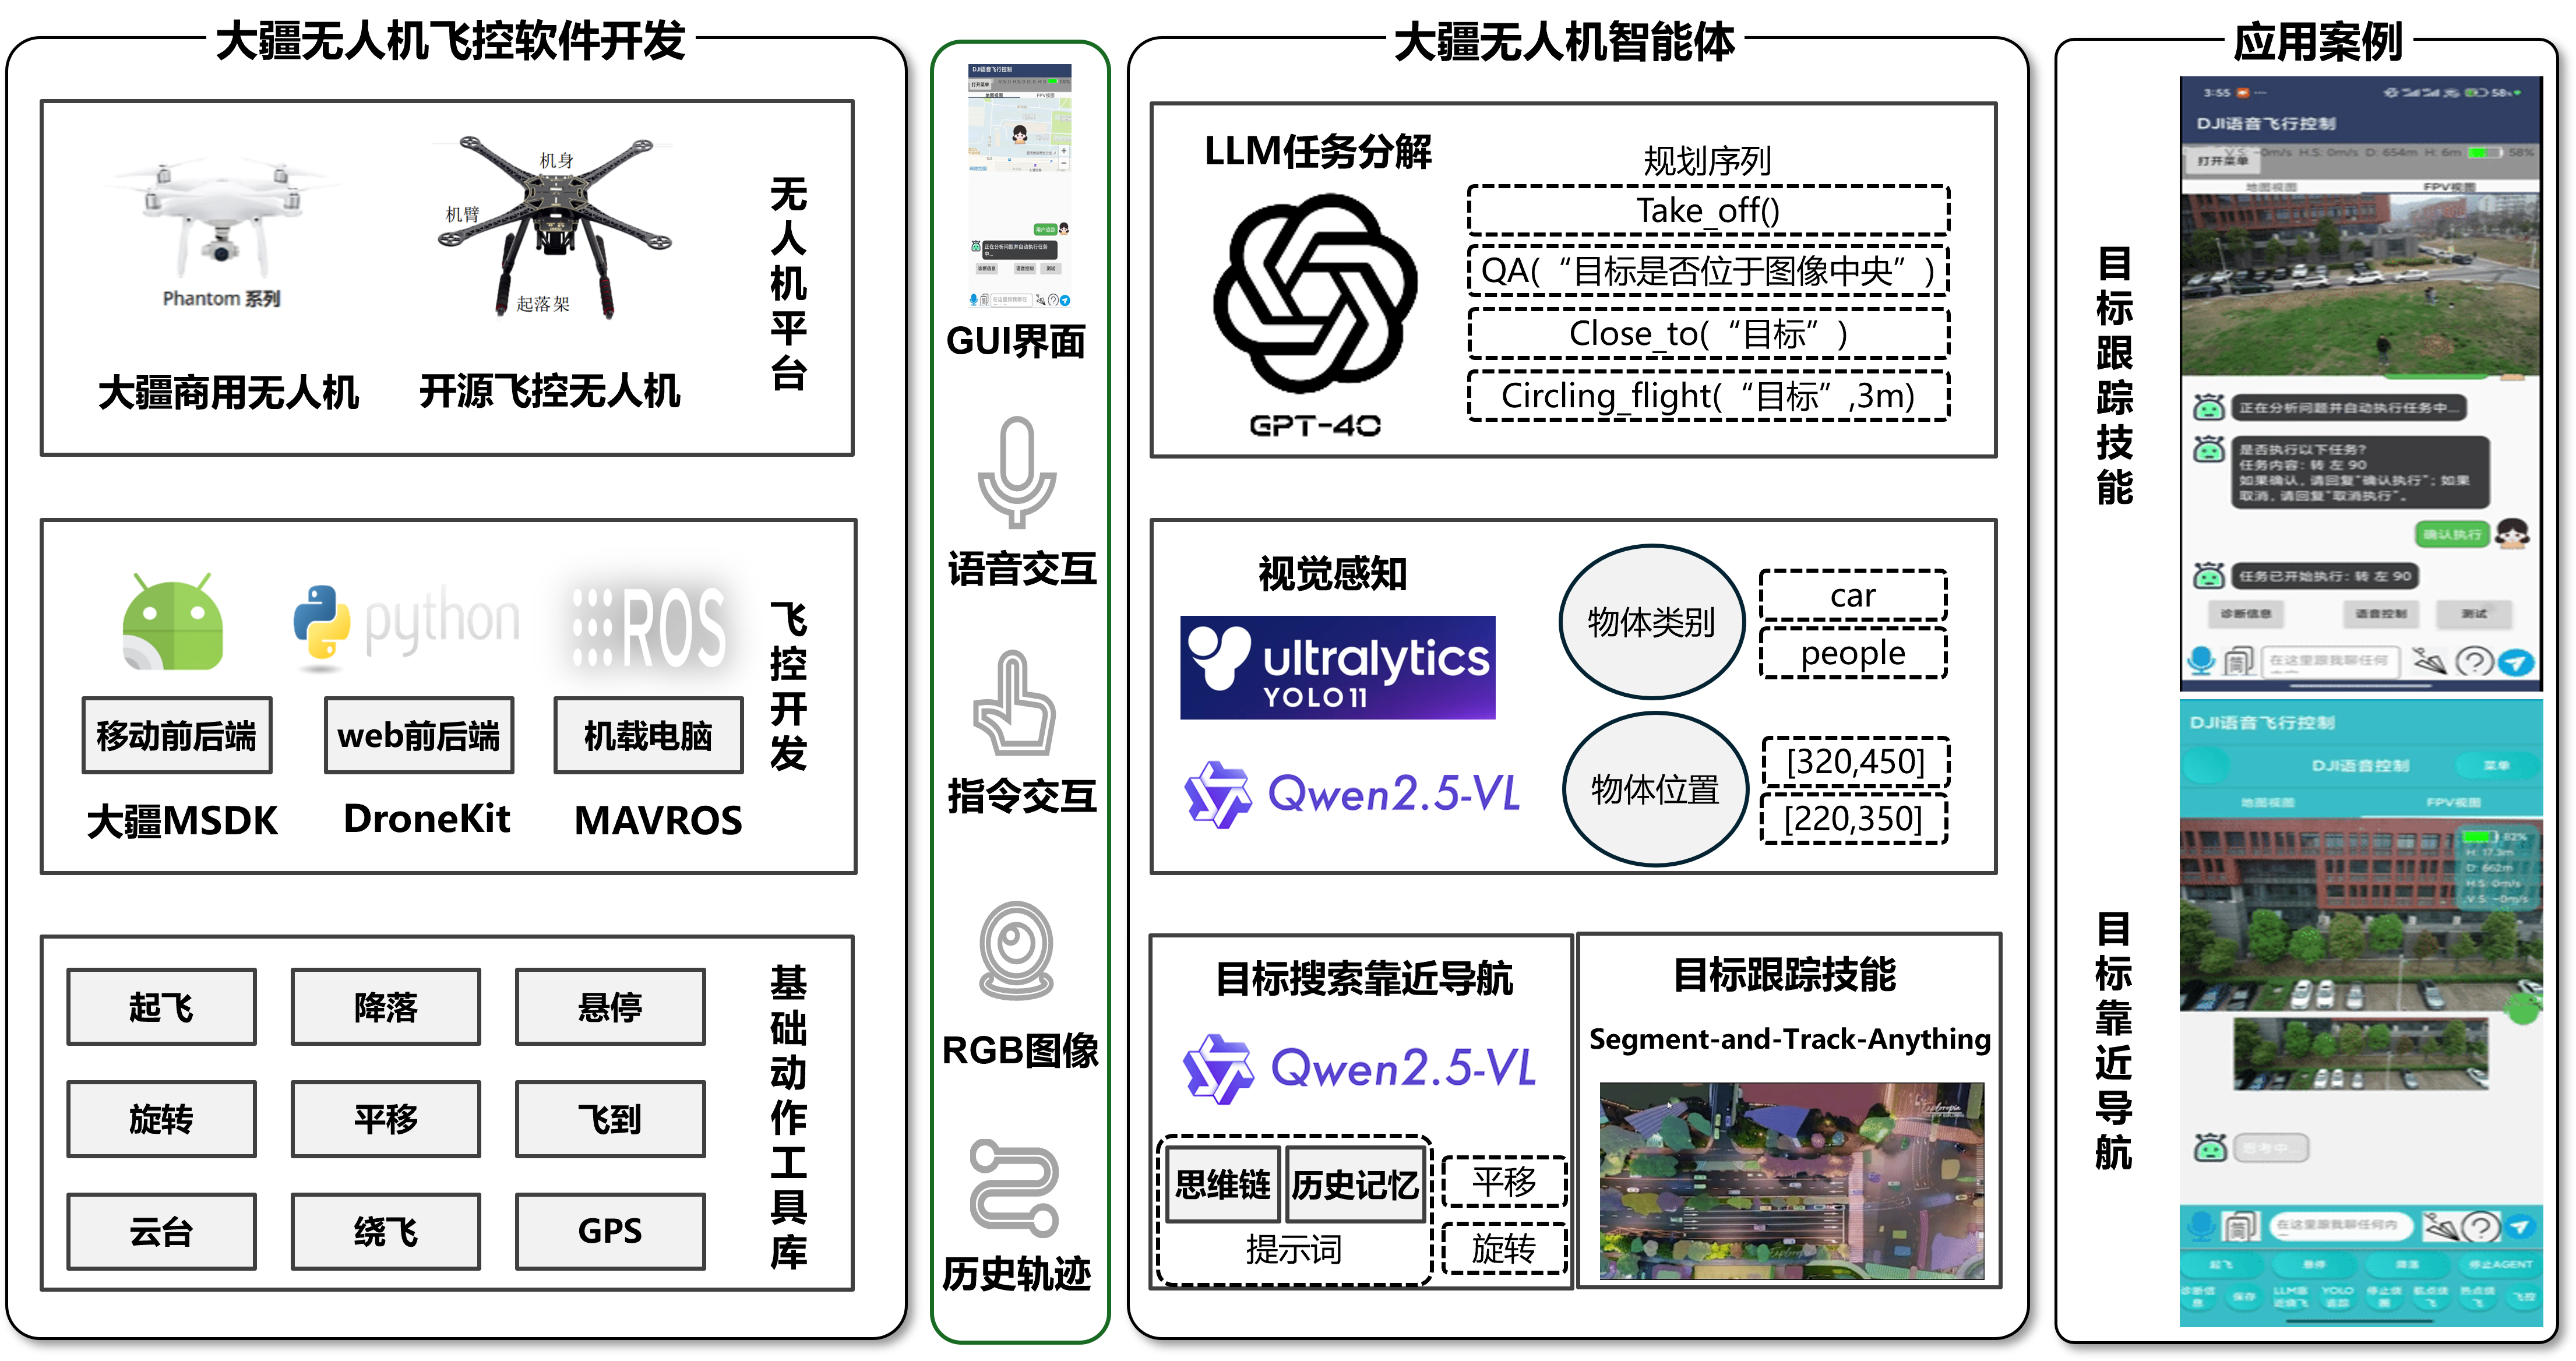
- Developed a model toolkit for semantic object detection, segmentation, and tracking. Applied chain-of-thought reasoning and perception-enhanced prompt engineering to improve the action reasoning and tool-use capabilities of vision-language models, increasing the completion rate of target information gathering and target tracking-and-approach tasks from 10% to 25%.
- Designed flight-control interfaces using the DJI Phantom SDK and developed an interactive Android app, establishing an end-to-end workflow spanning data collection, algorithm design, environment simulation, and real-world validation. The platform supported dynamic, real-world embodied-task data collection for the ISPRS 2026 (SCI Q1) journal paper BEDI: A Comprehensive Benchmark for Evaluating Embodied Agents on UAVs.
3D Reconstruction Using SLAM and Point Cloud Colorization
- Developed a SLAM system based on the FAST-LIO2 LiDAR-inertial odometry framework, addressing drift in long, straight corridors where geometric features are sparse. Colorized SLAM-generated point clouds through joint intrinsic-extrinsic calibration and temporal synchronization, enabling clearer, more accurate, and interpretable colored 3D maps.
- Designed a cart-based 3D reconstruction platform integrating sensors, onboard computing hardware, and mapping algorithms. The system supports an end-to-end workflow for simultaneous data acquisition and real-time mapping in long, corridor-like environments.
 Individual Awards
2025 - First-Class Graduate Scholarship, Central South University (RMB 10,000).
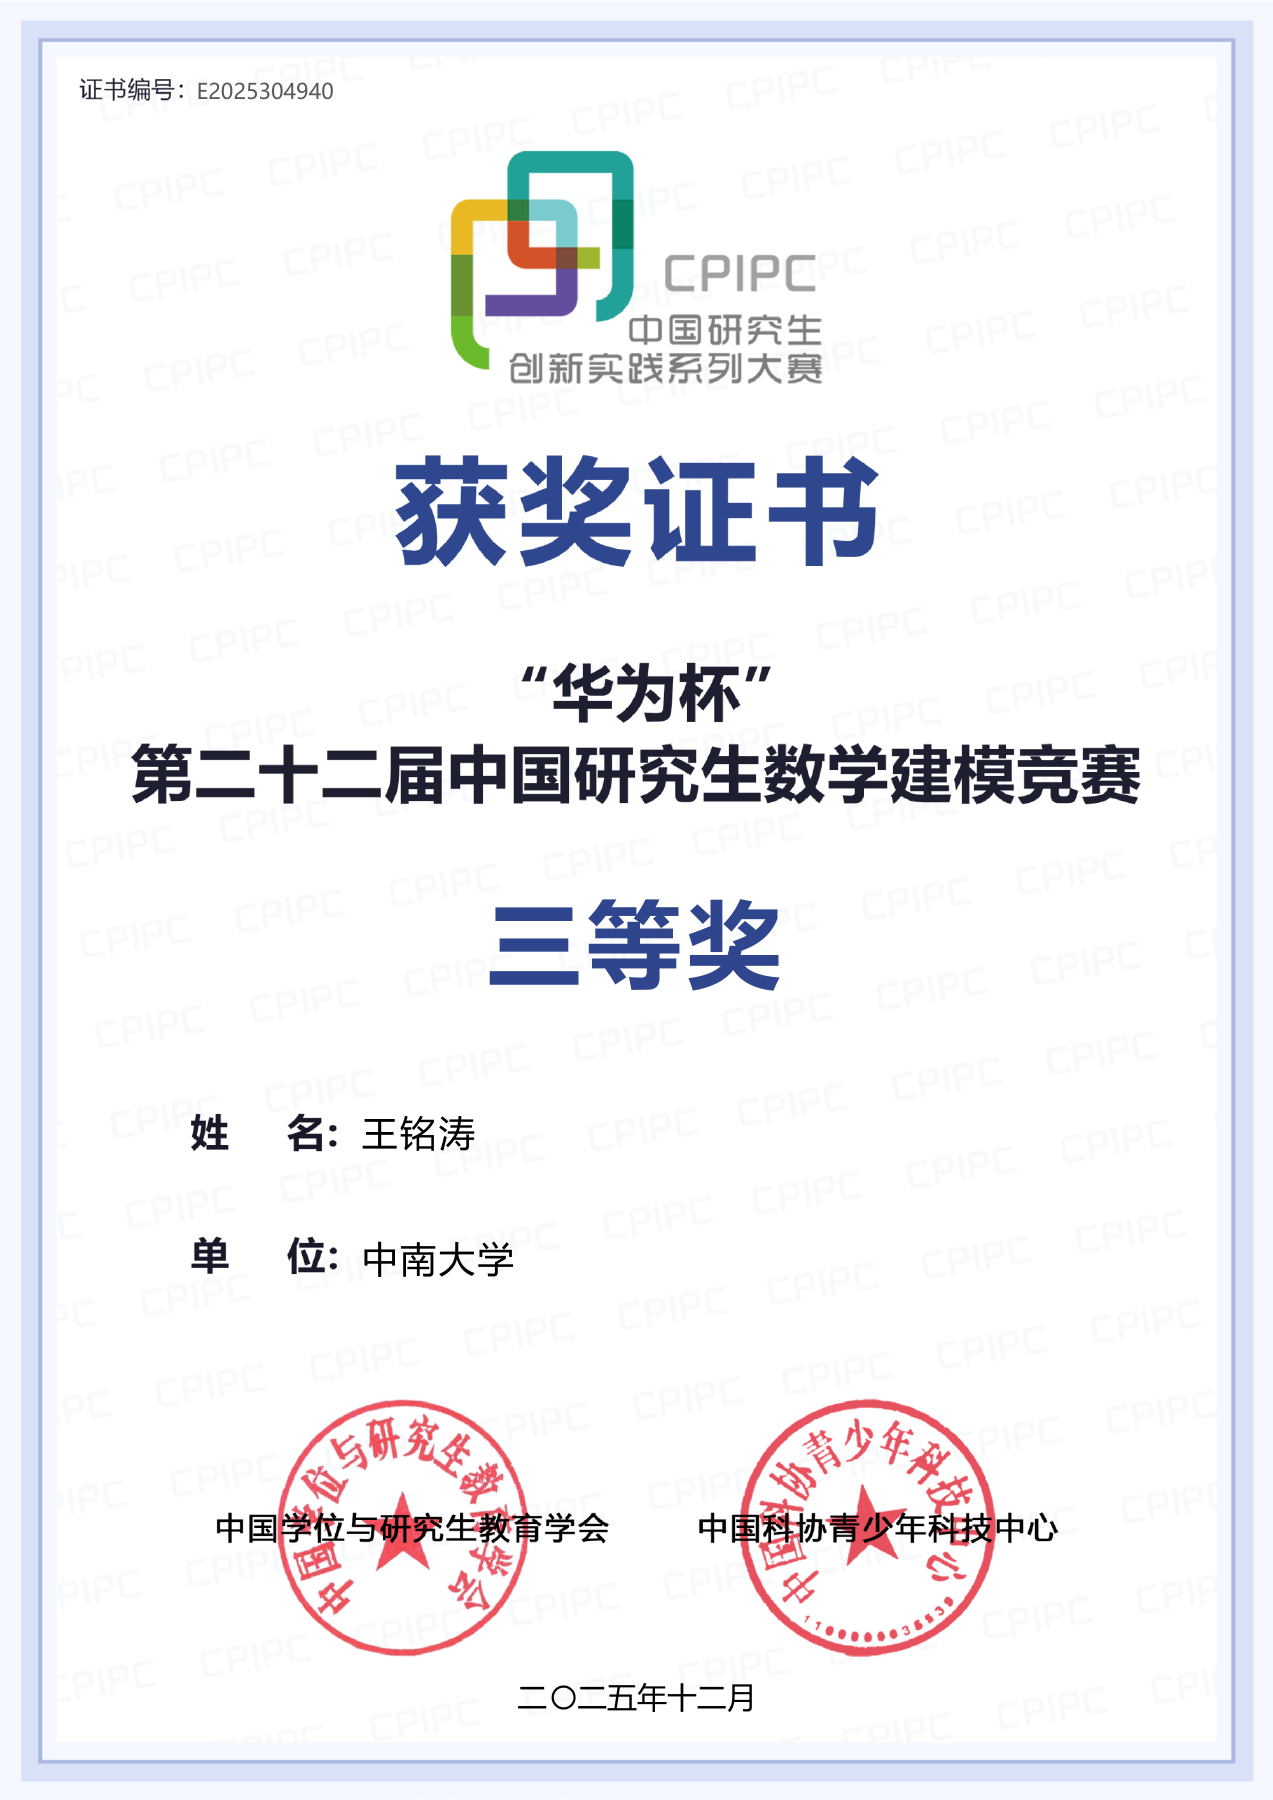
2025 - Third Prize, “Huawei Cup” China Graduate Mathematical Contest in Modeling (Top 20%, RMB 1,200).
2025 - Northeastern University Feiyue Education Scholarship (RMB 5,000).
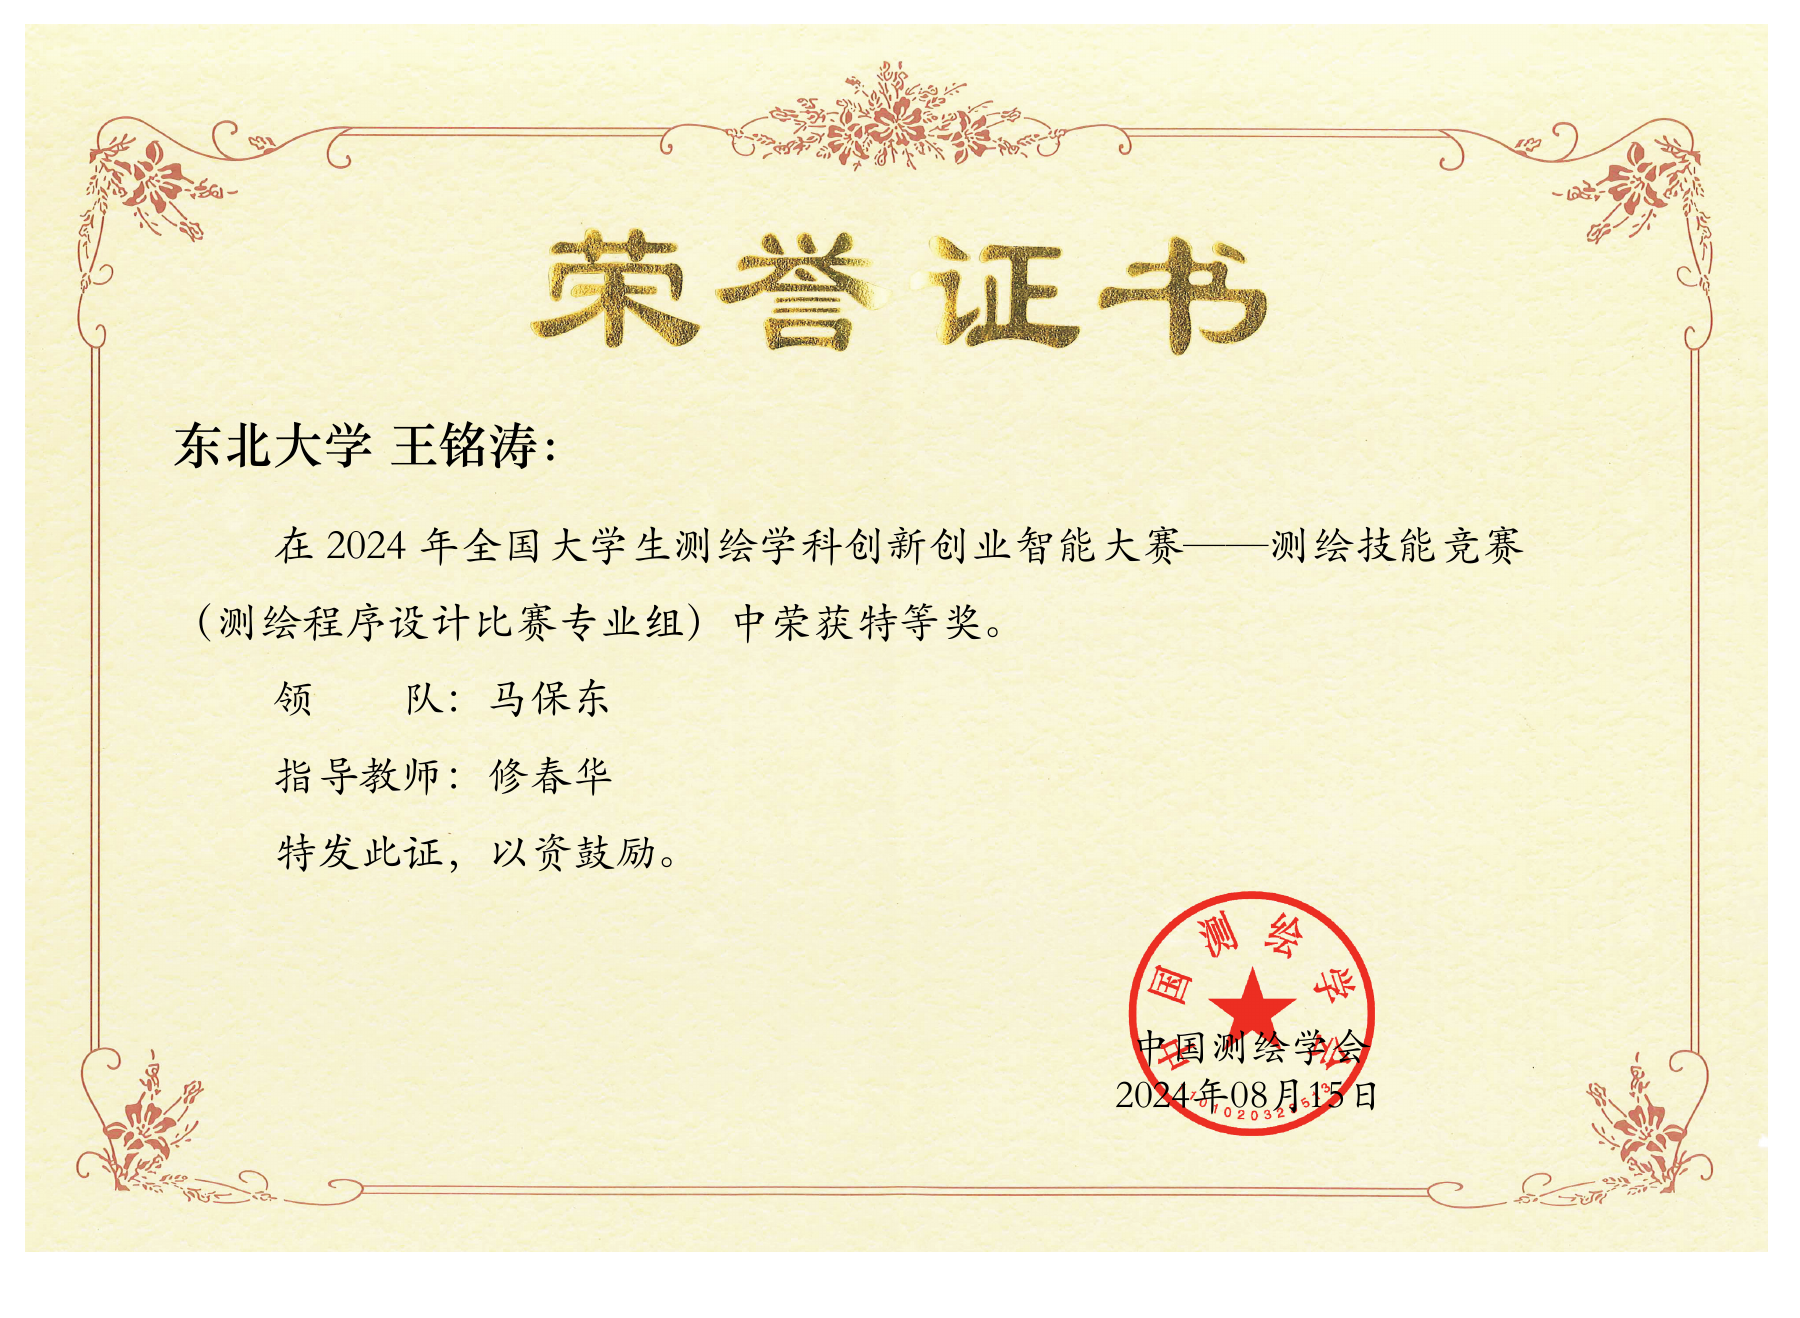
2024 - Grand Prize in Surveying and Mapping Programming, National College Students Surveying and Mapping Innovation and Entrepreneurship Intelligent Competition (10th out of 744 teams, Top 5%).
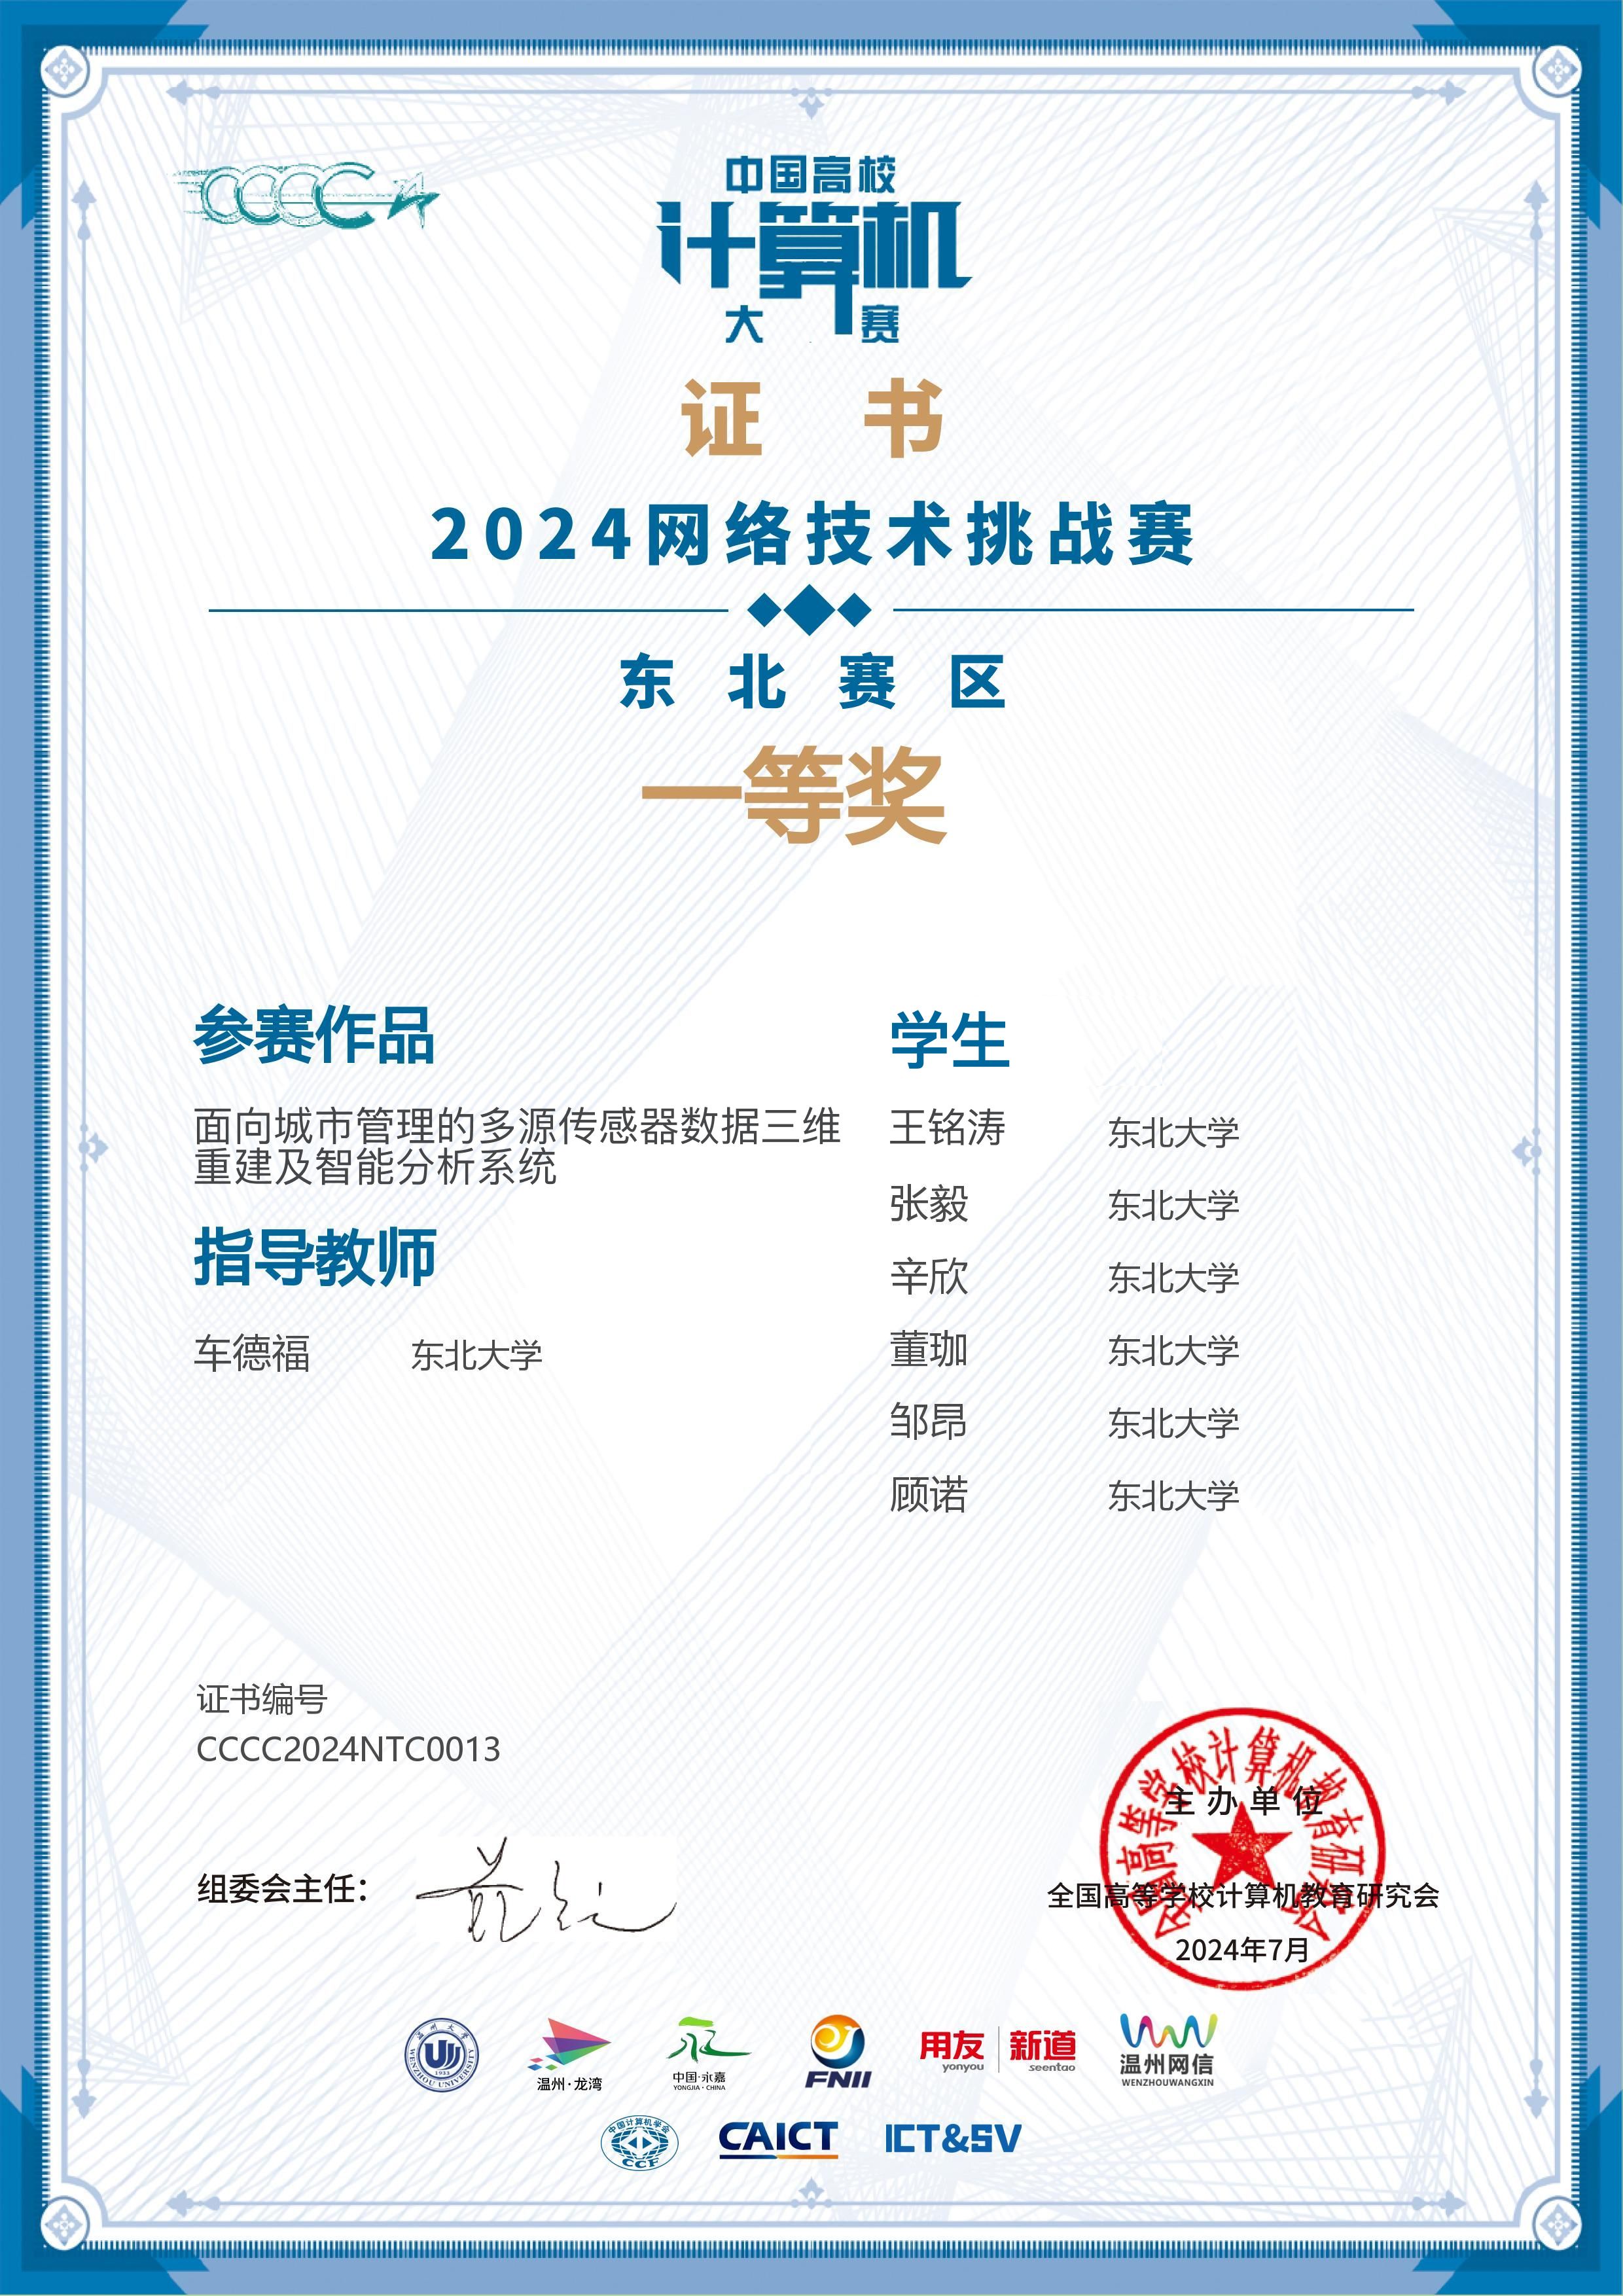
2024 - First Prize, Northeast Regional Competition, China Collegiate Computing Contest - Network Technology Challenge.
2024 - National Third Prize, China Collegiate Computing Contest - Network Technology Challenge.
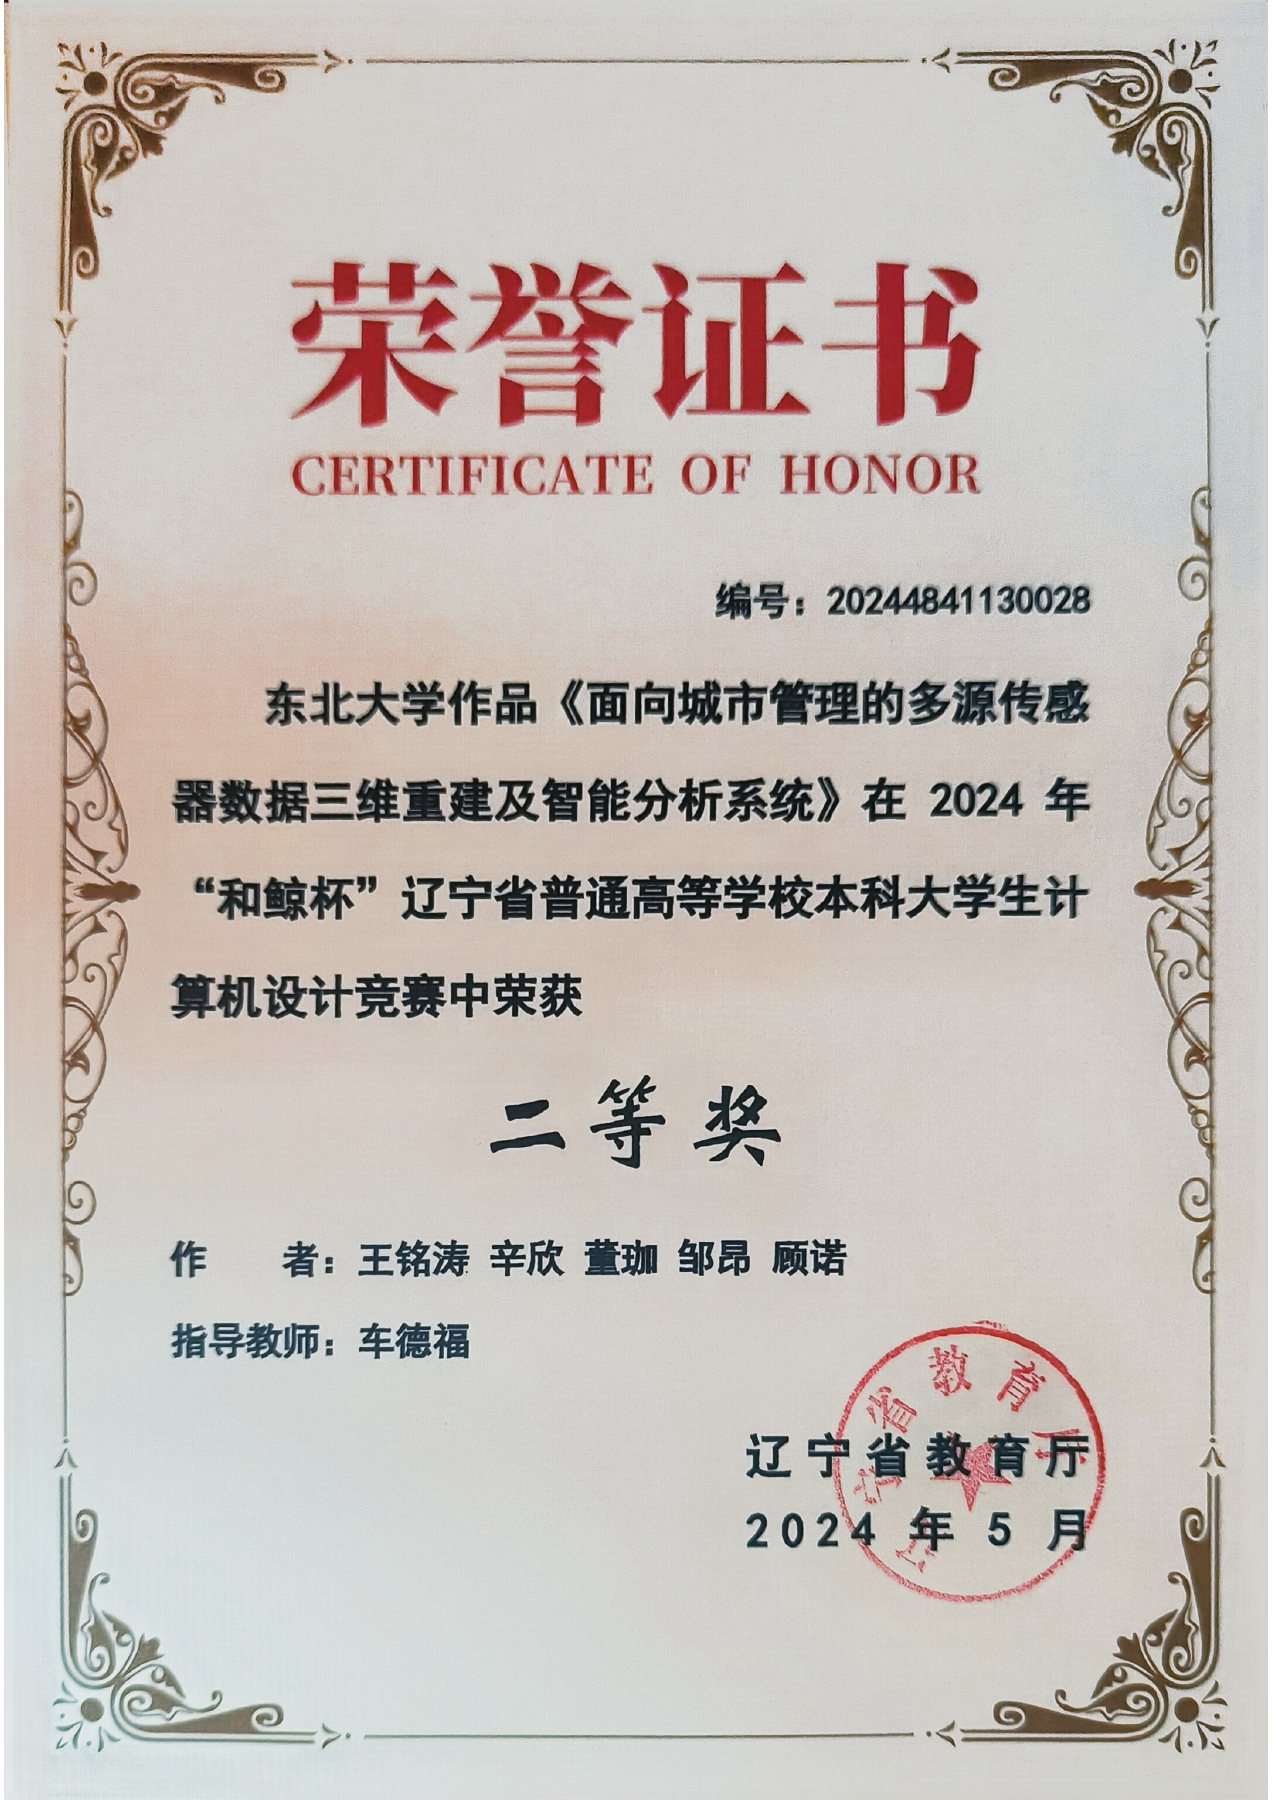
2024 - Provincial Second Prize, National College Student Computer Design Competition.
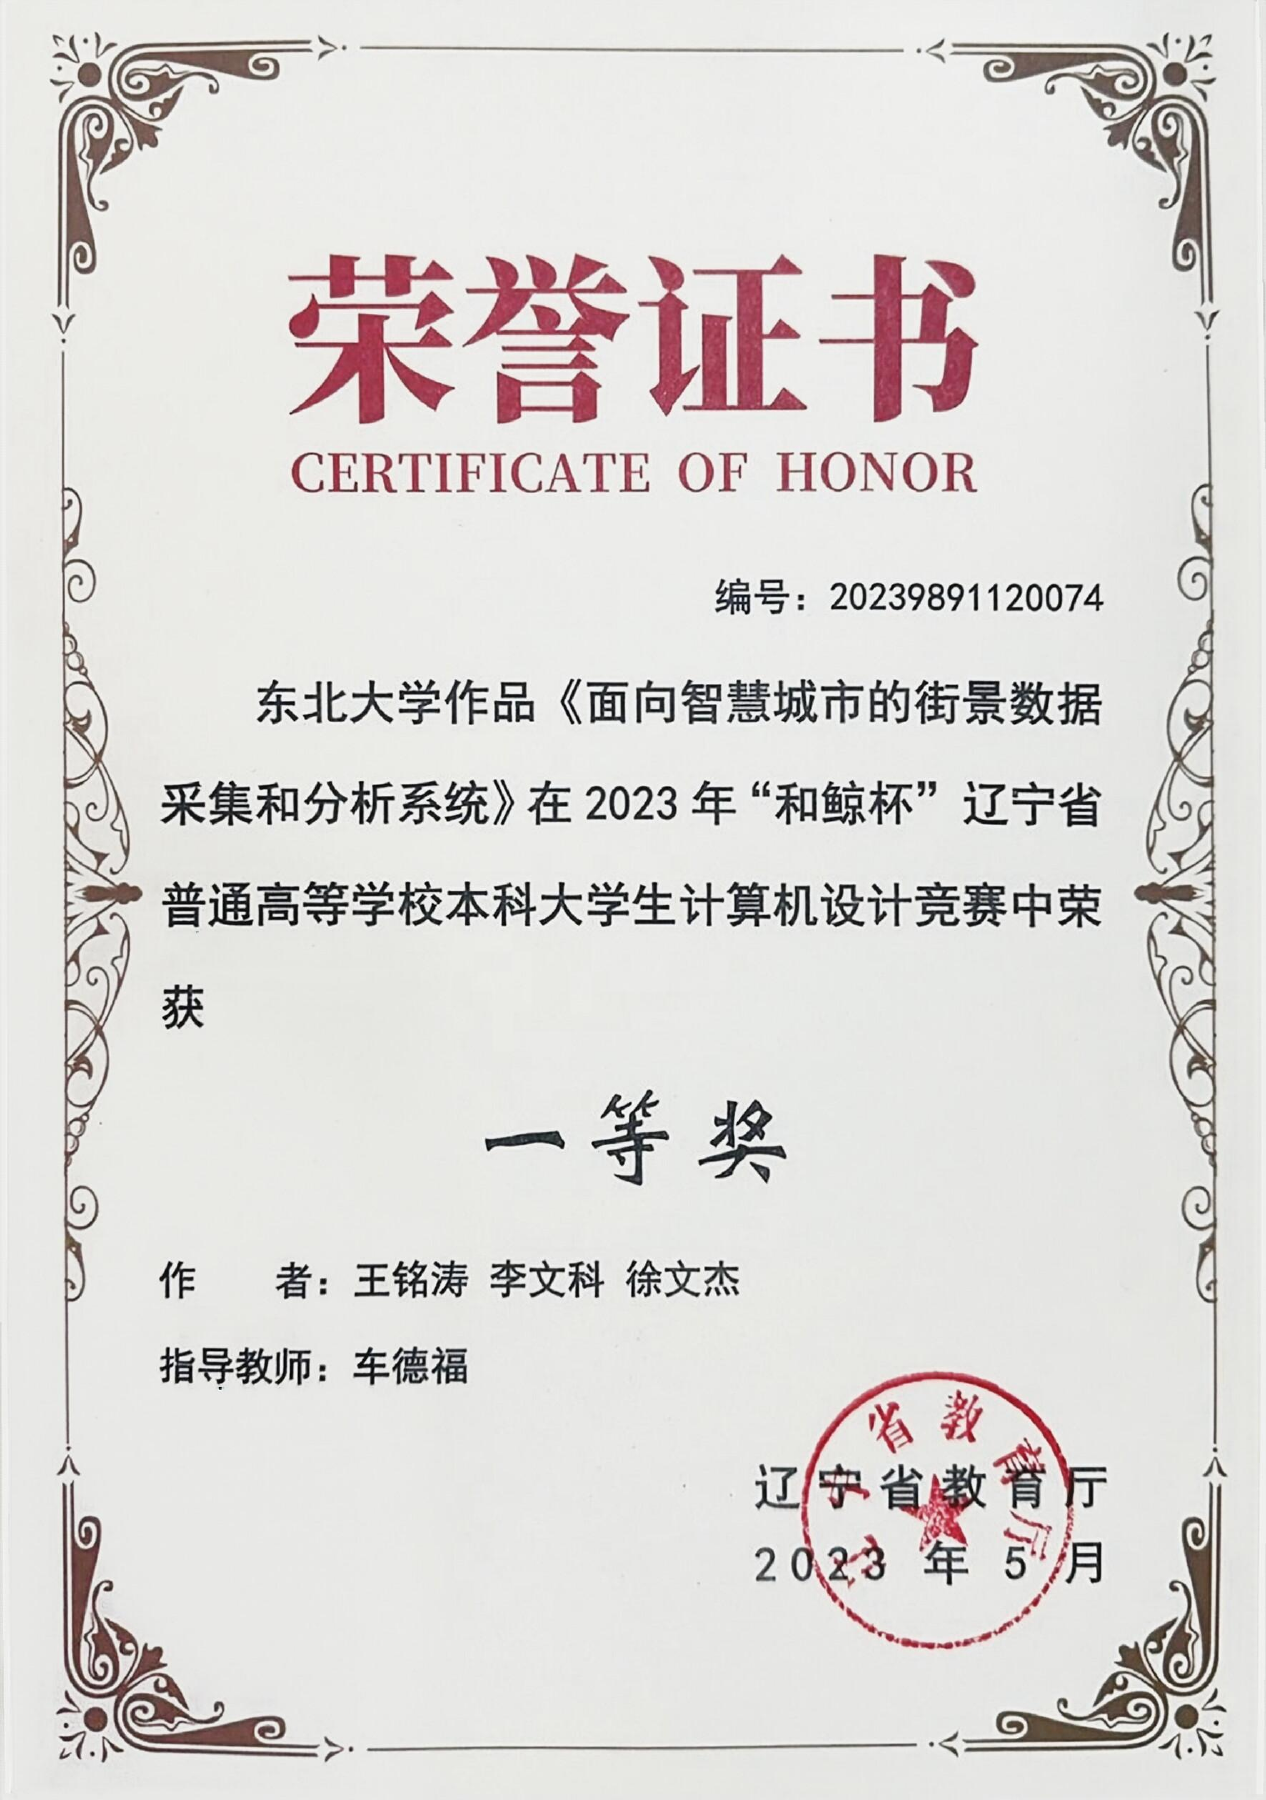
2023 - Provincial First Prize, National College Student Computer Design Competition.
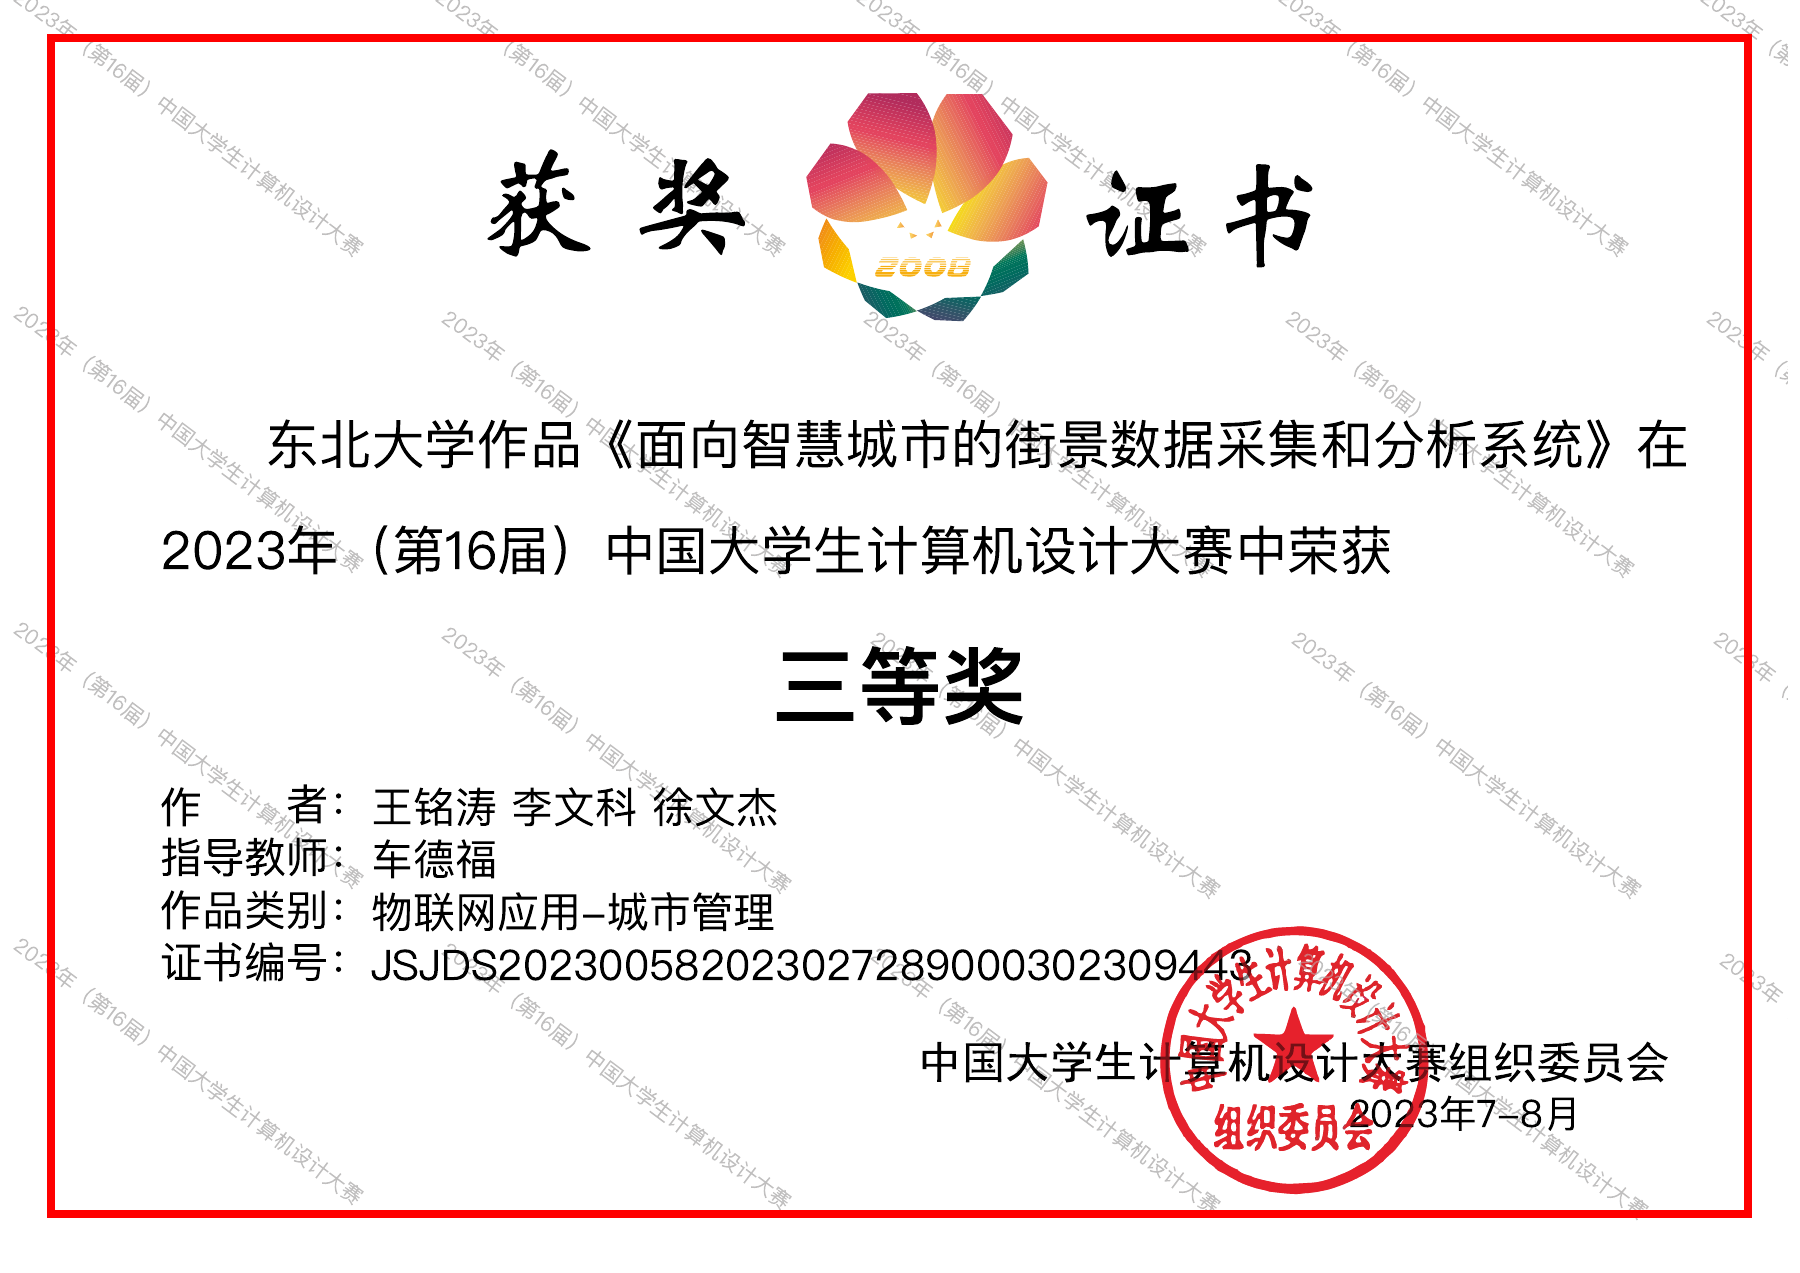
2023 - National Third Prize, National College Student Computer Design Competition.
2024 - Outstanding Individual for Academic Excellence, Northeastern University.
2024 - Jianlong Steel Named Scholarship (RMB 2,000).